

Nautobot Device Sync
Nautobot Device Sync: End-to-End Setup in rConfig V8.2.0
Section titled “Nautobot Device Sync: End-to-End Setup in rConfig V8.2.0”The V2 Nautobot driver pulls device inventory from a Nautobot server using its REST API and feeds it through the unified V2 pipeline. This guide follows the same model as the Statseeker V2 setup: only the Setup tab fields and upstream-side conventions are different.
| Platform | rConfig V8 Support | Auth supported | V2 Status |
|---|---|---|---|
| Nautobot | V8.2.0+ | API token | Field tested |
Mental Model: End Goal First
Section titled “Mental Model: End Goal First”The point of setting up a V2 integration is to land in a steady state where rConfig’s device inventory is continuously reconciled against Nautobot on a schedule, with no operator in the loop. That end state looks like this:
A Scheduled Task of type Integration V2 Job runs the Nautobot instance in Apply mode on a cron, e.g. nightly. It runs the same six-stage pipeline you’ll run interactively in this guide, writes any
createandupdatedecisions to rConfig, leaves any conflicts or ambiguous matches in Problem Devices for review, and notifies you on completion.
To get there, you walk a one-time setup and a sanity-check loop:
- Create the integration instance: Nautobot connectivity and auth in the Setup tab. Validate with Test Connection.
- Set up the Device Profiles the synced devices will inherit from. This happens under Inventory → Device Profiles, not in the integration itself.
- Run an Extract Preview to confirm filters return the right Nautobot devices.
- Run a Sync Preview to walk the full pipeline (canonicalize → reconcile → decide) without writing.
- Run a Full Sync (Apply) once the preview’s decisions look right.
- Schedule the integration to run on a cron from the rConfig scheduler.
%%{init: {'themeVariables': {'fontSize': '60px'}}}%%
flowchart LR
    A[Create instance<br/>Setup tab] --> B[Test Connection]
    B --> C[Device Profiles<br/>Inventory]
    C --> D[Extract Preview]
    D --> E[Sync Preview]
    E --> F[Full Sync · Apply]
    F --> G[Scheduled Task<br/>recurring sync]

  classDef step font-size:60px,stroke-width:2px;
  class A,B,C,D,E,F,G step;
Prerequisites
Section titled “Prerequisites”Nautobot:
- A reachable Nautobot server with the REST API enabled
- An API token for a service user with read access to
/dcim/devices/,/extras/tags/and/ipam/ip-addresses/ - Network connectivity from rConfig to Nautobot
- A custom field of type Text named
rconfig_device_profileadded to thedcim | devicecontent type: this is the field the V2 driver reads to resolve the Device Profile slug - Optional: tags and sites for upstream filtering
rConfig V8.2.0+:
- Administrator access
- A clear answer to: which Device Profile (vendor, category, template, credential set, optional SNMP group / Vector agent) every synced device should adopt by default
Step 1: Create the Integration Instance (Setup Tab)
Section titled “Step 1: Create the Integration Instance (Setup Tab)”1.1 Open the V2 driver picker
Section titled “1.1 Open the V2 driver picker”Navigate to Platform → Integrations. Scroll to the Device Sync section and click + Add Driver under V2 Drivers. The picker shows every V2 driver split into Configured Drivers and Not Configured Yet.
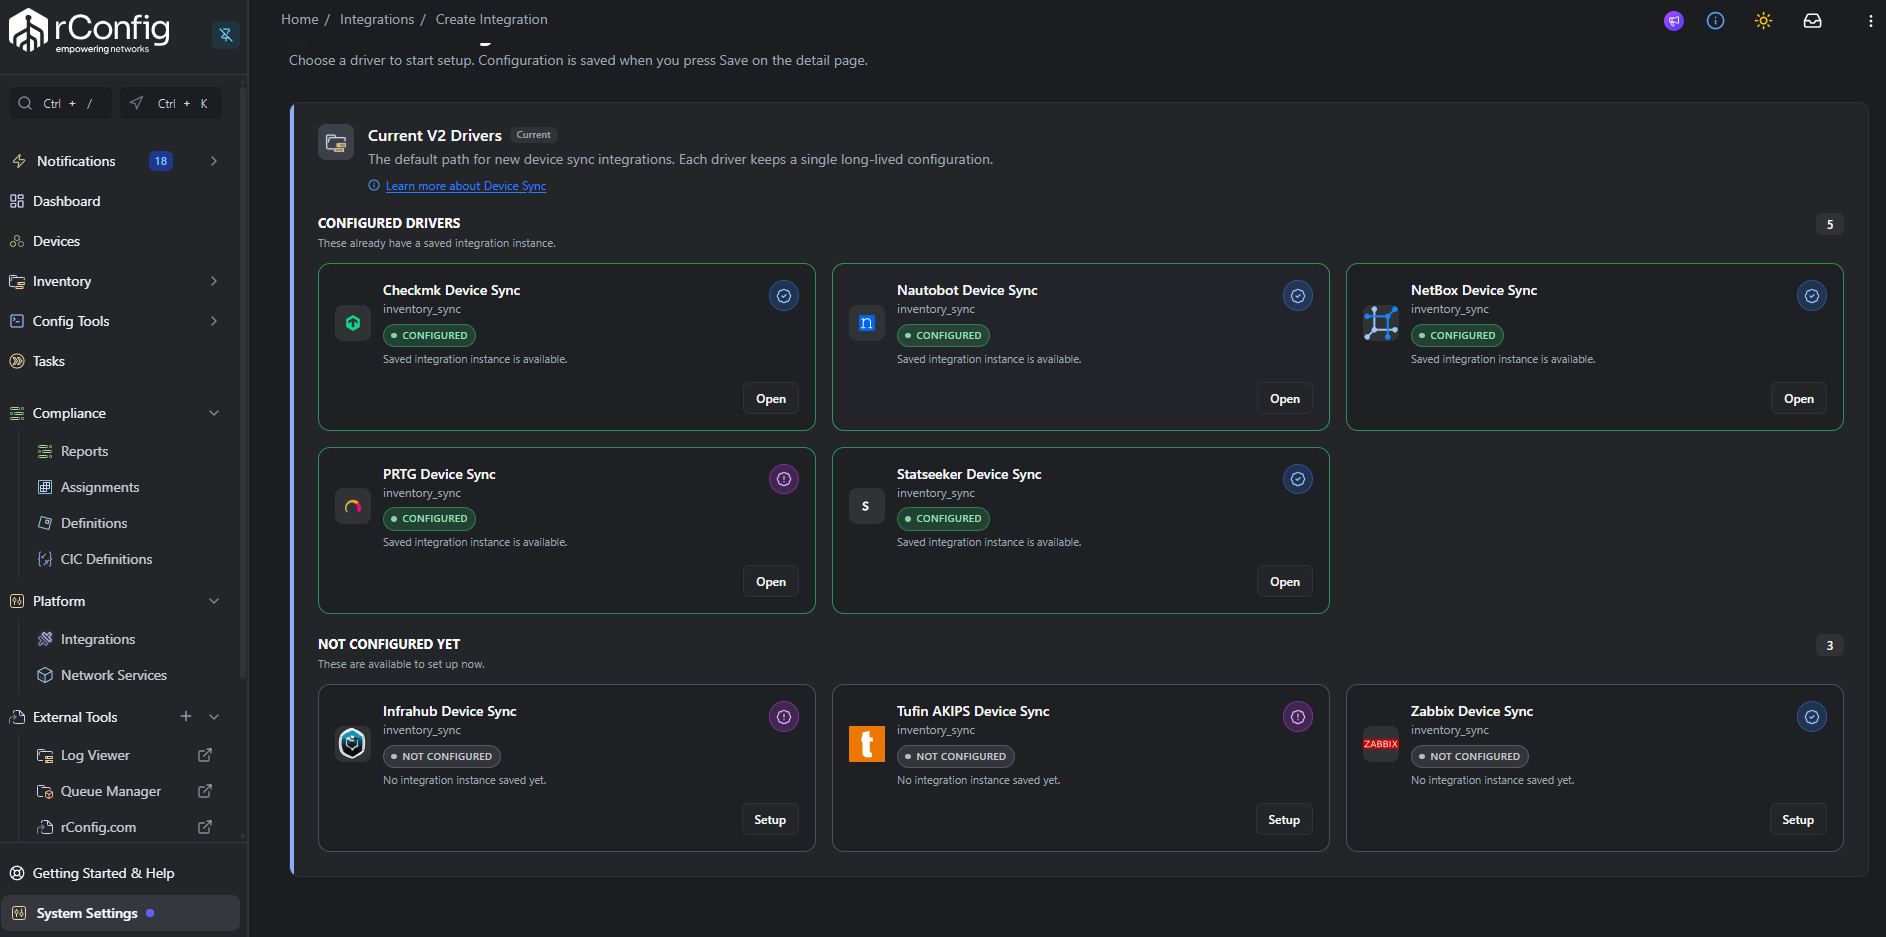 V2 driver picker. Shown with Zabbix highlighted. Pick Nautobot from the same list.
Each card carries the driver’s verification badge (Field tested for Nautobot), plus a link to its docs page. Click the Nautobot card.
1.2 Fill in the schema-driven Setup tab
Section titled “1.2 Fill in the schema-driven Setup tab”The driver picker drops you straight into the instance Detail page on the Setup tab. The form is rendered from nautobot.schema.php and is laid out in two sections.
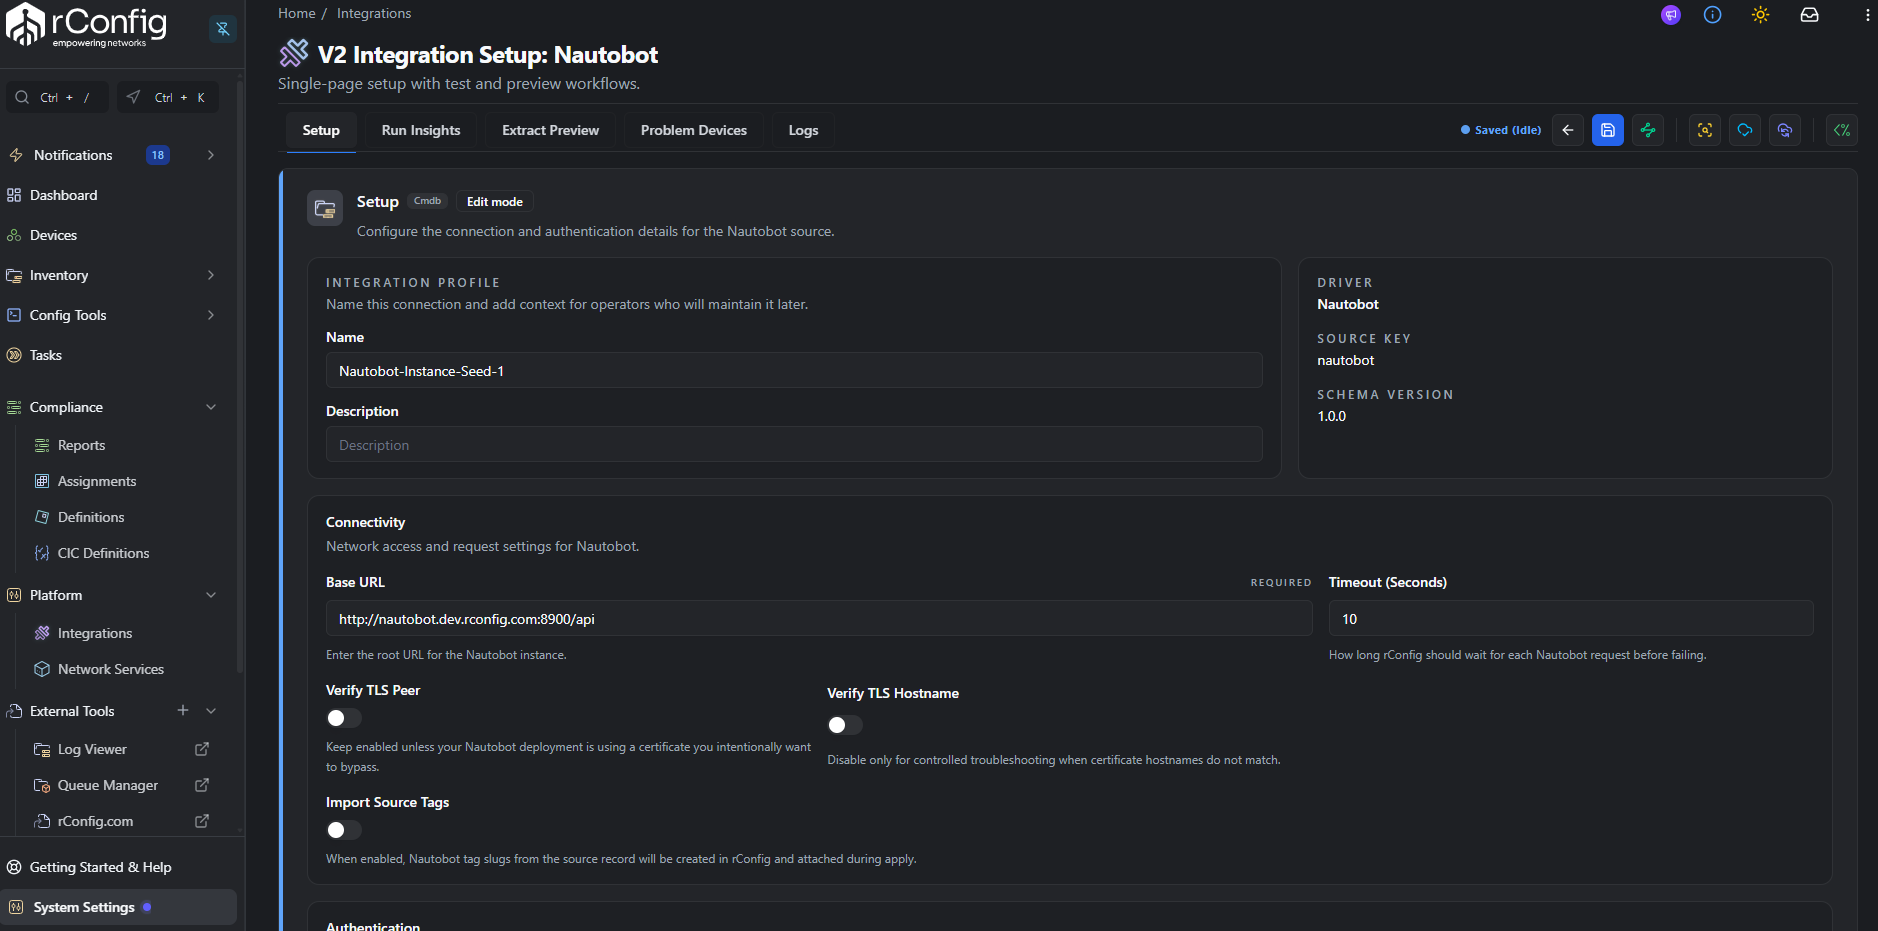
Connectivity
| Field | Default | Notes |
|---|---|---|
| Base URL | required | Root of the Nautobot server, e.g. https://nautobot.example.com. No trailing slash needed. |
| Timeout (Seconds) | 30 |
HTTP request timeout. Range 1–120. |
| Verify TLS Peer | on |
Leave on for production. Disable only for self-signed labs. |
| Verify TLS Hostname | on |
Leave on for production. Disable only for hostname mismatches in labs. |
| Import Source Tags | off |
When on, Nautobot tag slugs become canonical tags in rConfig and are attached on Apply. |
| Prefer NAT (Outside) IPv4 | off |
When on, devices are managed on their primary IPv4’s NAT (outside) address if Nautobot has one. See Devices behind NAT. |
Authentication
- API Token (required). Generated under Admin → Users → Tokens in Nautobot. Stored as a secret. The driver sends it as
Authorization: Token <api_token>.
Devices behind NAT
Section titled “Devices behind NAT”From V8.4.1, the Nautobot driver can manage a device on its NAT address instead of its primary IPv4. Use this when the primary IPv4 in Nautobot is a remote-site address rConfig can’t reach, but the same IP has a NAT (outside) address that is reachable from your network.
Turn on Prefer NAT (Outside) IPv4 and save. On each run the driver fetches the primary IPv4’s record from /ipam/ip-addresses/{id}/, reads its NAT (outside) addresses (nat_outside_list), and uses that IPv4 as the device IP in rConfig. If there are several, the lowest one is used so the choice doesn’t change between runs. Devices with no NAT (outside) address keep their primary IPv4, and so does any device whose lookup fails.
In Nautobot, set the NAT relationship on the outside address: edit the reachable IP and set its NAT (Inside) field to the device’s primary IPv4.
rConfig doesn’t test which address is reachable. It uses the NAT address whenever Nautobot has one. Because the setting is part of the integration, every sync applies it again, so a re-sync never puts the primary IPv4 back.
1.3 Test the connection
Section titled “1.3 Test the connection”Click Test Connection in the action bar at the top of the page.
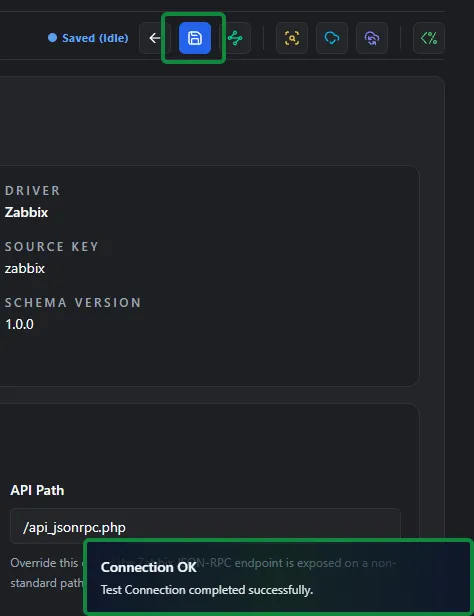 Setup tab after a successful Test Connection (green status pill). Shown with the Zabbix driver. The Nautobot screen is the same.
The driver hits GET /dcim/devices/?limit=1. Common failures:
| What you see | Most likely fix |
|---|---|
| Connection refused / timeout | Wrong Base URL or firewall in between rConfig and Nautobot. |
SSL / certificate error |
Self-signed cert: toggle Verify TLS Peer / Hostname off (lab only). |
401 / 403 |
Token revoked, expired, or scoped to a user without dcim.view_device permission. |
404 |
API not reachable at the expected path: check Nautobot reverse proxy / sub-path config. |
1.4 Save
Section titled “1.4 Save”Click Save. The runtime config is written to integration_instances.runtime_config and the auth material is stored via secrets_ref. The save indicator in the action bar flips to Saved once persisted.
Step 2: Set Up Device Profiles (Inventory)
Section titled “Step 2: Set Up Device Profiles (Inventory)”Device Profiles live outside the integration. They are the rConfig-side definition of what a synced device should look like: vendor, category, device template, credential set, optional SNMP group and Vector agent. Each profile has a slug; the V2 driver matches the upstream record’s custom_fields.rconfig_device_profile value to that slug to pick the profile.
2.1 Open the Device Profiles page
Section titled “2.1 Open the Device Profiles page”Navigate to Inventory → Device Profiles.
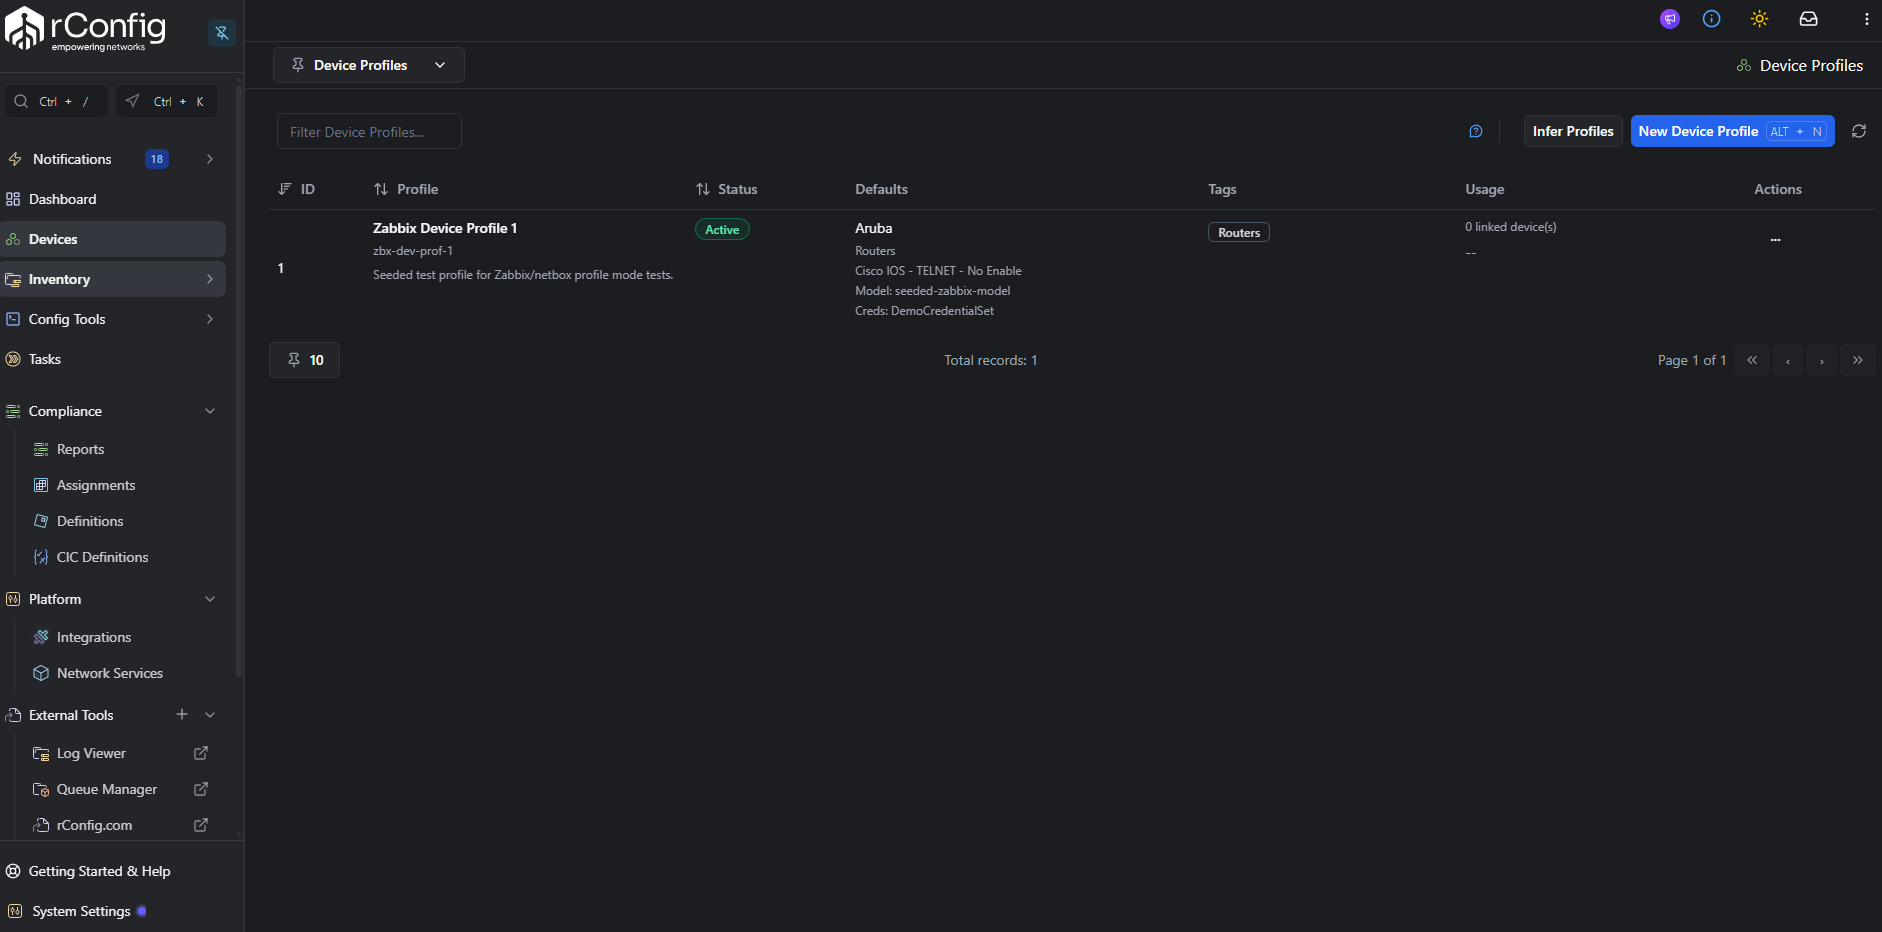
2.2 Create a Device Profile per device class
Section titled “2.2 Create a Device Profile per device class”For each device class you want to sync (e.g. Cisco IOS Core Routers, Arista Edge Switches), click New Device Profile and fill in:
- Name: human-readable.
- Slug: the value Nautobot’s
rconfig_device_profilecustom field will reference. - Vendor, Category, Template, Credential set: standard rConfig device classification.
- SNMP group, Vector agent, default tags, default model / prompt patterns: optional.
2.3 Populate the custom field on the Nautobot side
Section titled “2.3 Populate the custom field on the Nautobot side”The Nautobot V2 driver reads the profile slug only from custom_fields.rconfig_device_profile (nautobot.schema.php → device_profile.source_profile_paths). Tags and groups are not used for profile resolution in this driver: the custom field is authoritative.
In Nautobot:
- Navigate to Extensibility → Custom Fields → + Add.
- Content types:
dcim | device. - Type:
Text. - Name:
rconfig_device_profile(must match exactly). - Save.
- Open each device, set the
rconfig_device_profilecustom field to the matching rConfig Device Profile slug (e.g.cisco-ios-core).
If you cannot tag every device immediately, set a default profile on the Nautobot integration instance so untagged devices inherit a sensible fallback.
Step 3: Run an Extract Preview
Section titled “Step 3: Run an Extract Preview”Switch to the Extract Preview tab (amber download icon in the action bar).
Extract Preview hits Nautobot exactly the way a real sync would, but stops the moment the records come back: no canonicalize, no reconcile, no writes.
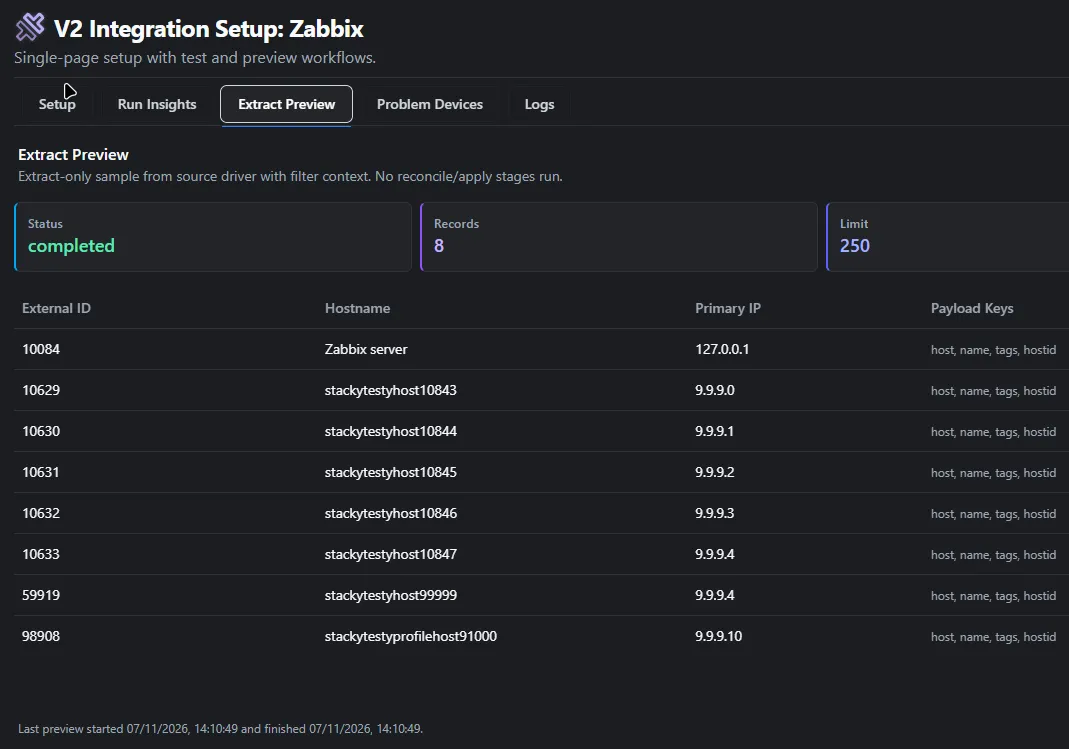 Extract Preview tab with summary cards and result table. Shown with the Zabbix driver. The Nautobot screen is the same.
Nautobot supports filters on:
tag(operators:equals,in,contains_all,contains_any)site(operators:equals,in)status(operators:equals,in)
Open a row’s Details hover to see the full raw payload: confirm name, the chosen IP field (primary_ip4.address or primary_ip.address) and the custom_fields.rconfig_device_profile value used for profile resolution are all present.
For the full anatomy of this tab, see the Extract Preview Tab reference.
Step 4: Run a Sync Preview
Section titled “Step 4: Run a Sync Preview”Click Preview Sync in the action bar (sky icon). Sync Preview runs the complete pipeline through decide and stops without writing.
Switch to the Run Insights tab to inspect the result.
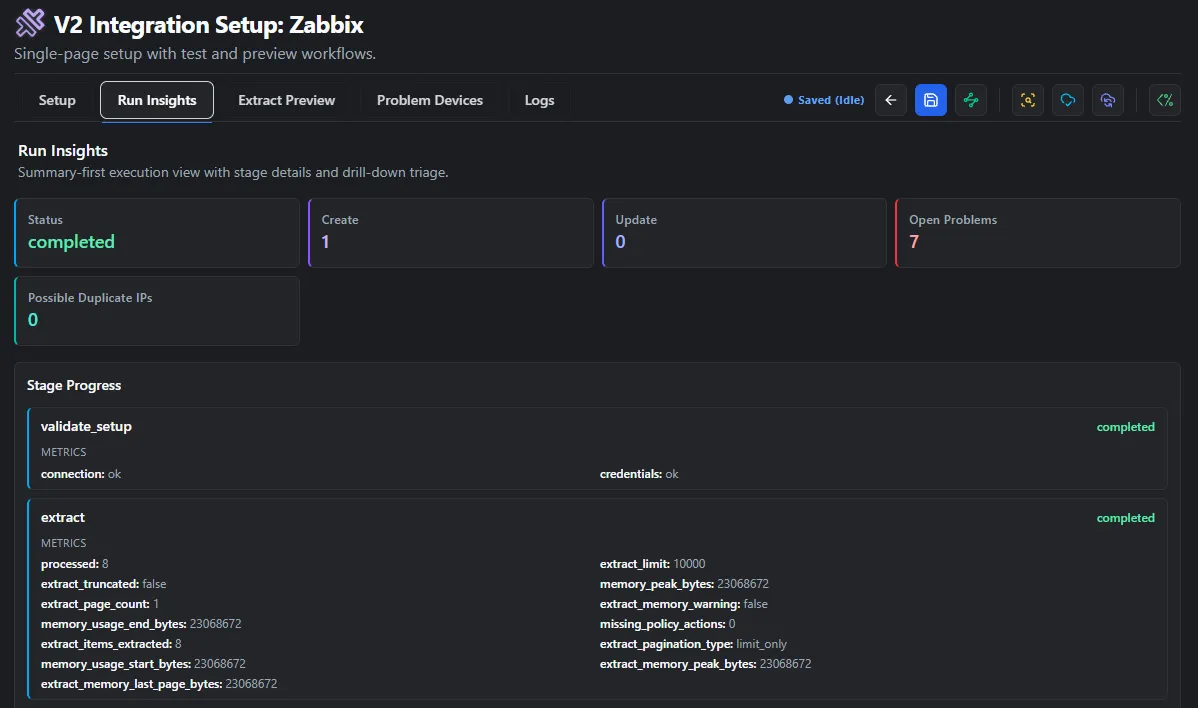 Run Insights tab populated after a Sync Preview. Shown with the Zabbix driver. The Nautobot screen is the same.
For Nautobot the most-watched stage metrics are:
extract.items_extracted: should match the Extract Preview count (within filter scope).canonicalize.invalid: non-zero usually means a device has noprimary_ip4/primary_ipset, or therconfig_device_profilecustom field is empty / doesn’t resolve.reconcile.ambiguous: non-zero means more than one rConfig device matches the same Nautobot device.
If Open Problems is greater than zero, switch to the Problem Devices tab and triage the rows.
For the full anatomy of these tabs, see the Run Insights Tab reference and Problem Devices Tab reference.
Step 5: Run a Full Sync (Apply)
Section titled “Step 5: Run a Full Sync (Apply)”When the Sync Preview decisions look correct and Open Problems is at an acceptable level, click Full Sync in the action bar (indigo icon).
Full Sync re-runs the full pipeline and finishes by executing the apply stage:
- Creates new devices for each
decision = create. - Updates existing devices for each
decision = update. - Assigns the resolved Device Profile to each affected device.
- Syncs canonical tags onto the device when Import Source Tags was on at Setup.
- Updates
integration_device_links(first_seen,last_seen). - Schedules an initial configuration backup for newly created devices.
Run Insights tab after a Full Sync, with the apply stage card populated. Shown with the Zabbix driver. The Nautobot screen is the same.
Re-check Problem Devices after Apply: Apply does not auto-resolve ambiguous_match or conflict rows; those still need a human.
Step 6: The Debug Console
Section titled “Step 6: The Debug Console”For any of the runs above, you can swap the action-bar button for the Open Debug Console button (shimmer icon). The Debug Console runs the same Artisan command synchronously and streams its native stdout/stderr into a modal:
 Debug Console modal mid-run. Shown with the Zabbix driver. The Nautobot screen is the same.
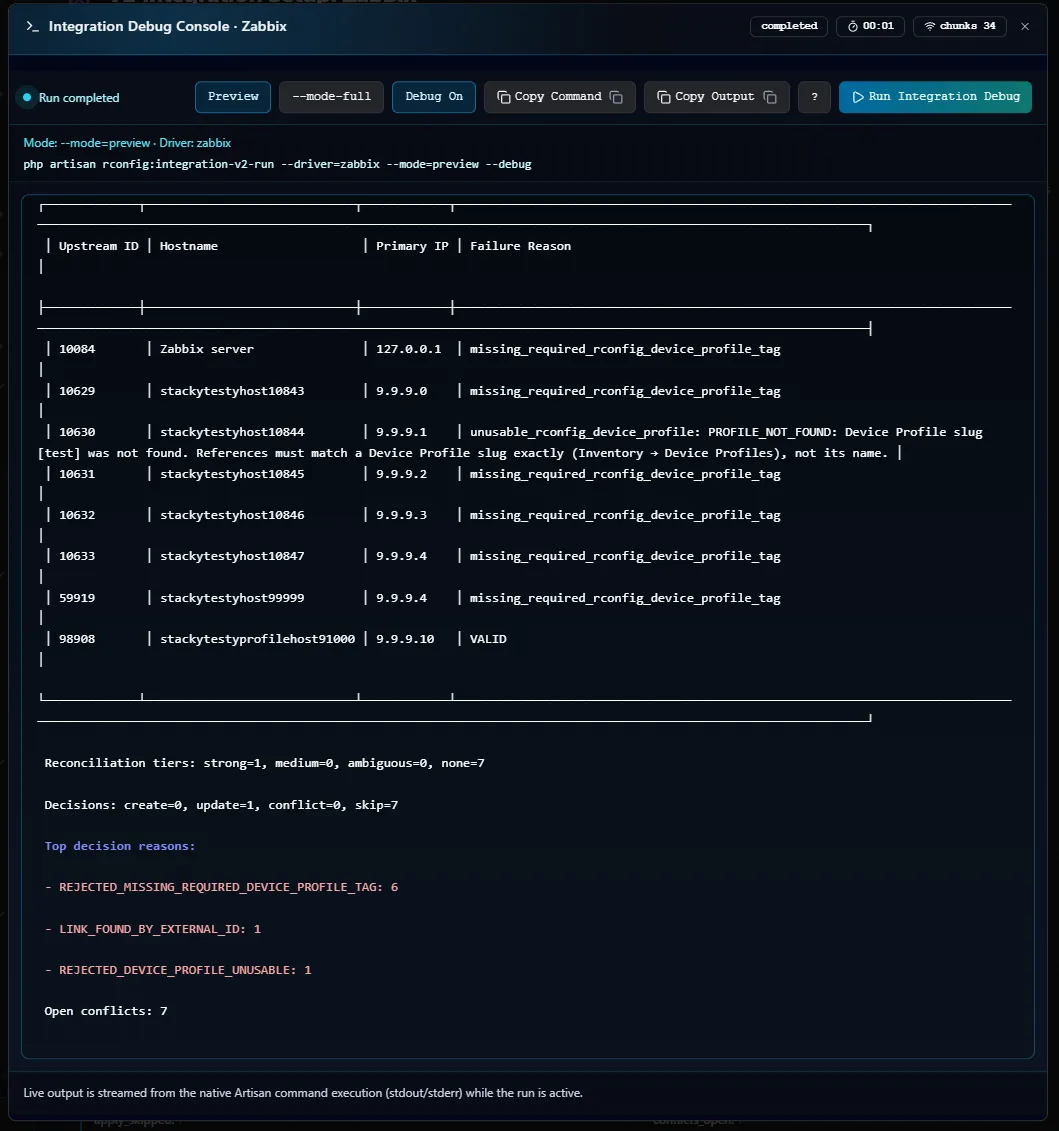 Debug Console modal after a run completes. Shown with the Zabbix driver. The Nautobot screen is the same.
For the full anatomy of the dialog, see the Debug Console reference.
Step 7: Schedule the Sync
Section titled “Step 7: Schedule the Sync”Once a manual Full Sync completes cleanly, schedule it. Navigate to Tasks and click New Task. Choose task type Integration V2 Job, pick the Nautobot instance, choose Apply mode, and set the cron schedule.
A common production pattern:
- Hourly Preview: drift detection only, no writes.
- Nightly Apply: commits real changes during the maintenance window.
CLI Reference
Section titled “CLI Reference”# Sync Preview (does not write)php /var/www/html/rconfig8/current/artisan rconfig:integration-v2-run --driver=nautobot --mode=preview
# Full Sync (Apply) by explicit instance ID, with debug outputphp artisan rconfig:integration-v2-run 14 --mode=apply --debug
# Queue an async runphp artisan rconfig:integration-v2-run 14 --mode=apply --queueDriver Reference
Section titled “Driver Reference”Nautobot fields the driver reads
Section titled “Nautobot fields the driver reads”| Canonical field | Nautobot payload paths checked, in order |
|---|---|
| External ID | id |
| Hostname | name |
| Primary IP | NAT (outside) IPv4, only with Prefer NAT (Outside) IPv4 on → primary_ip4.address → primary_ip.address |
| Serial | serial |
| Vendor | device_type.manufacturer.name |
| Model | device_type.model |
| Tags | tags[*].slug |
| Profile slug | custom_fields.rconfig_device_profile (declared schema path) |
If the upstream returns tag IDs instead of objects, the driver fetches each tag via /extras/tags/{id}/. Same for IP addresses via /ipam/ip-addresses/{id}/.
Reconciliation policy
Section titled “Reconciliation policy”- Strong match: by
instance_link_external_id(Nautobotid) or an exact global serial match. - Medium match: hostname and primary IP both unique in rConfig.
- No automatic medium-match auto-relink, no cross-family matching.
Missing upstream policy
Section titled “Missing upstream policy”The default mode is disable_link_only: when a previously-synced Nautobot device disappears from the upstream, rConfig disables the integration_device_links row but leaves the device intact.
Troubleshooting
Section titled “Troubleshooting”- Connection works, credentials fail. Confirm the API token is active in Nautobot and the owning user has
dcim.view_devicepermission. Tokens scoped to a single object permission group can pass/dcim/devices/?limit=1but fail when reading tags or IPs: give the user broad read access. - Extract returns zero devices. Re-check
tag/site/statusfilters and the API user’s object permissions. Nautobot will silently filter records the user cannot see. - Canonicalize flags candidates as invalid. Most common:
primary_ip4not assigned on the device, orcustom_fields.rconfig_device_profileempty / pointing at a Device Profile that doesn’t exist. - Profile resolution fails. Confirm the custom field is named exactly
rconfig_device_profile(lowercase, underscore), is attached to thedcim | devicecontent type, and its value matches an active rConfig Device Profile slug. - Reconciliation produces ambiguous matches. Two rConfig devices share the same hostname or primary IP. Resolve in Problem Devices by picking the correct target, or de-duplicate the device list.
- Device imported with an IP rConfig can’t reach. If the primary IPv4 is a remote-site address and Nautobot records a reachable NAT address for it, turn on Prefer NAT (Outside) IPv4. If the device still gets the primary IP, check that the NAT address’s NAT (Inside) field points at the primary IPv4 and that the API token can read IP addresses.
- Slow runs. Hydration of tag and IP IDs is the usual cause. Ensure your Nautobot API serializer is returning inline objects where possible, or accept the extra wall-clock for large inventories.